Understand the space
Explore how perception can locate people, objects, obstacles, and useful work areas.
H-SERIES · HUMANOID
The flagship SAIREX humanoid concept, created to learn how intelligent machines can perceive, move, and work in human environments.
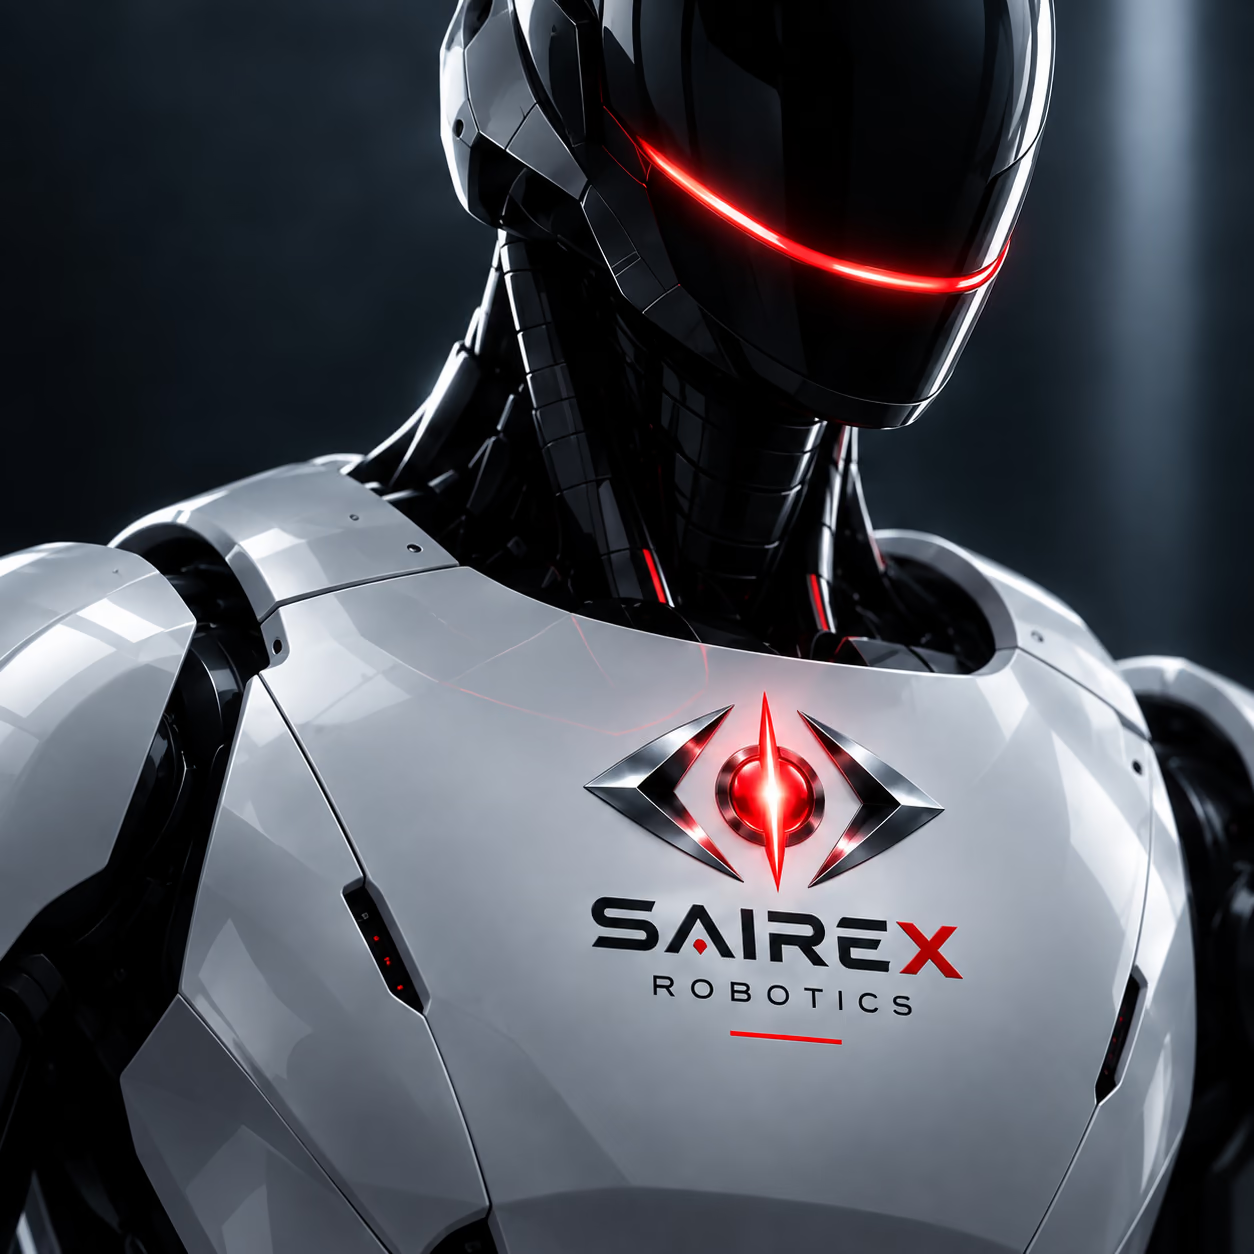 CONCEPT VISUAL · FORM SUBJECT TO CHANGE
DIRECTION
Capabilities described here are development goals, not a specification sheet. They will be updated as prototypes are built and validated.
DEVELOPMENT PATH
System definition is the current public focus. Later stages will be marked active only when the work supports that claim.
PUBLIC ENGINEERING SCOPE
The early program is organized around a few foundational questions. These are workstreams, not confirmed product specifications.
Explore how perception can locate people, objects, obstacles, and useful work areas.
Study balance, coordinated motion, and manipulation in a human-scale body.
Connect perception, planning, and action into a repeatable physical workflow.
A direction for multimodal awareness of people, objects, and space.
Research toward stable, coordinated motion and manipulation.
A modular approach to planning, learning, and completing physical tasks.
Safety, legibility, and human-scale interaction guide the product direction.
The Building H1 journal will separate completed work, active development, and future intent.
Follow the H1 build